Jogging
Jogging moves one axis at a time: a single joint, or a single Cartesian axis of the tool center point, in the robot base frame or in the tool frame.
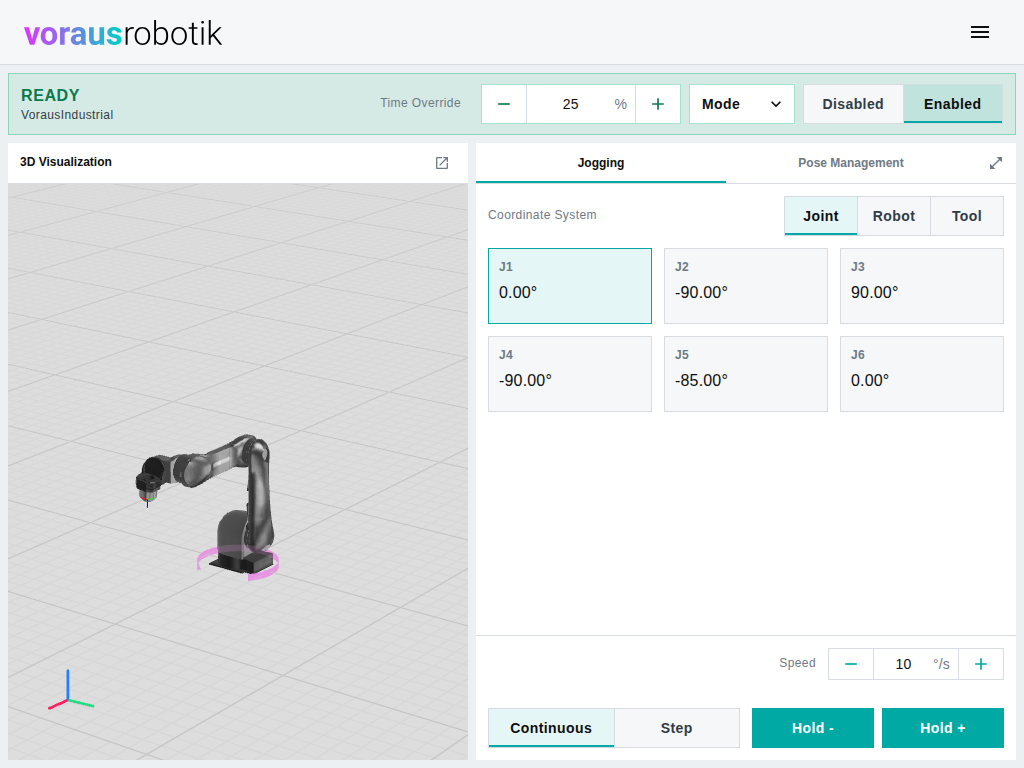
Joint lists the joints of the robot. Robot and Tool list the six Cartesian axes of the tool center point: Robot moves along the axes of the robot base frame, Tool along the axes of the tool frame, which turn with the tool. In both cases the tiles show the pose of the tool center point in the robot base frame. Click a tile to select the axis. The 3D visualization draws a magenta arrow along it, so you see where Hold + will move the robot. The selection is remembered per coordinate system.
In Continuous mode, Hold - and Hold + move the axis in the negative or positive direction while pressed. In Step mode (Figure 2), Step - and Step + move the axis by one step per press. Keep the button pressed until the step is complete. If you release it early, the robot stops where it is.
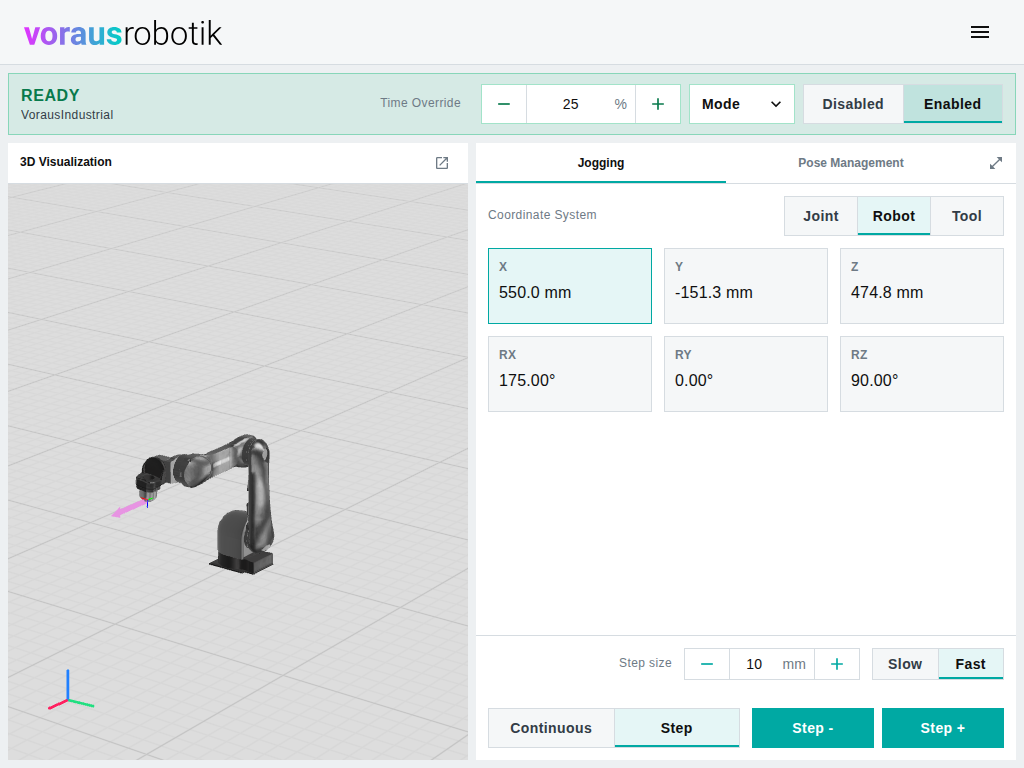
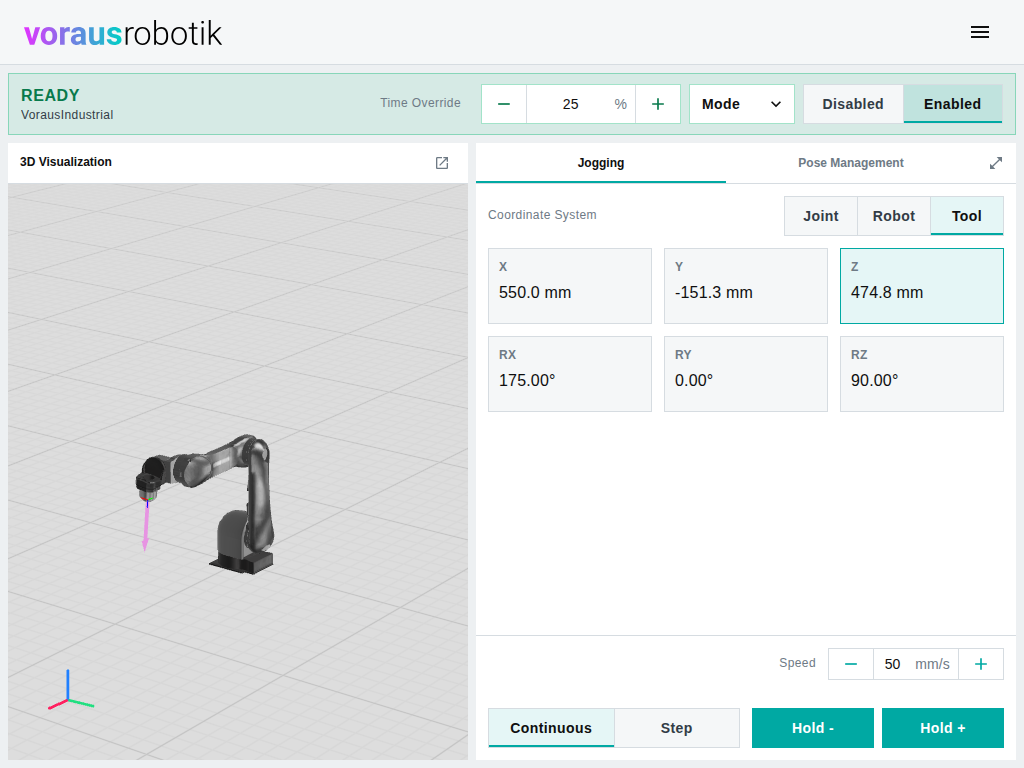
The row above the buttons sets the speed or the step size. The minus and plus buttons walk through the presets, which depend on the mode and on whether the selected axis rotates or translates. You can also type a value into the field, it applies as you type:
| Mode | Rotating axis | Translating axis |
|---|---|---|
| Continuous, Speed | 0.1, 1, 10, 25 °/s | 0.1, 1, 50, 100 mm/s |
| Step, Step size | 0.1, 0.5, 1, 5° | 0.1, 1, 10, 25 mm |
A typed speed stays within the presets, a typed step size can exceed them. A step beyond a limit of voraus Robot Control ends in an error.
Speed and step size are remembered separately for rotating and translating axes. In step mode, Slow and Fast next to the step size set how fast a step runs: Fast, the default, at the speed voraus Robot Control allows for manual motion, Slow at about 3 % of the axis speed limits. The speed of continuous jogging stays as it is. The Time Override applies on top.
Robot limits
The Advanced view (menu at the top right of the app bar) shows the active limits of voraus Robot Control in every tile. The choice is kept per browser.
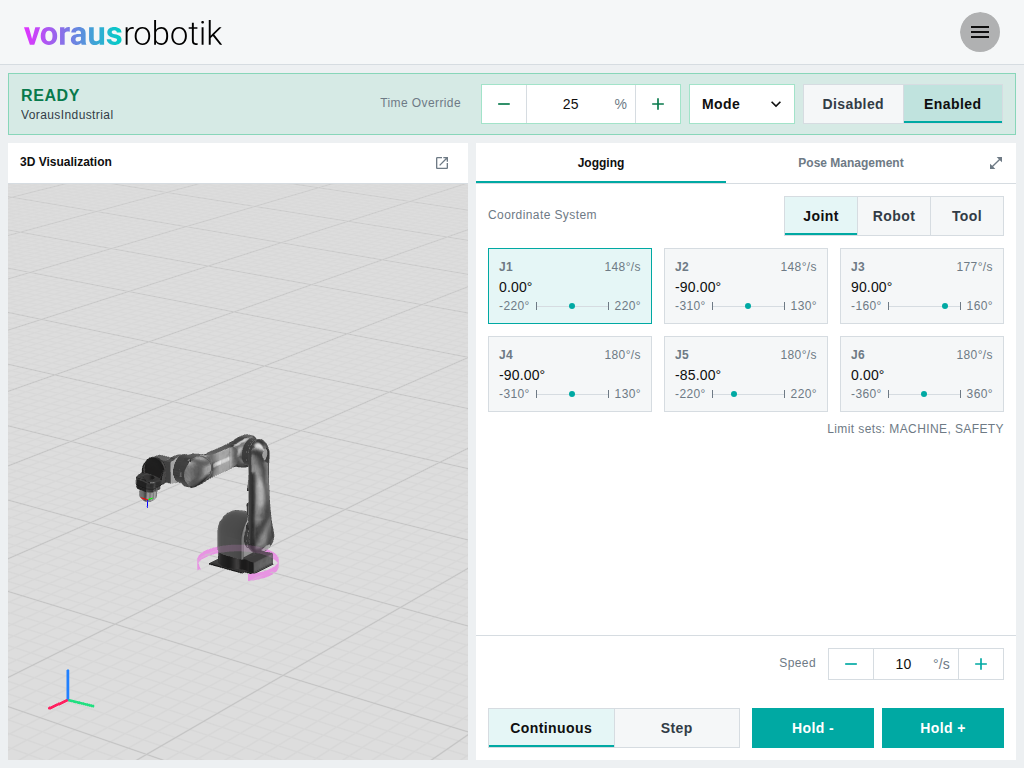
- Speed limit in the top right corner of a tile is the speed limit of the axis. Narrow tiles show only the number.
- The scale under the value runs from the minimum to the maximum position, the dot marks the current value. Within 5 % of a limit, the dot and that end turn orange, beyond it red.
- Joints show their position range and speed limit. X, Y and Z show the workspace cuboid and the translational TCP speed limit, RX, RY and RZ only the rotational one. Limits that are not configured are left out.
Limit sets below the tiles names the limit sets Robot Control is currently monitoring.